Zhuowei Xu

Meche Master @CMU | Tactile Sensing | Manipulation

prof_pic.jpg

Hello! I am Zhuowei Xu, a recent M.S. graduate in Mechanical Engineering from Carnegie Mellon University. I am currently a research assistant working with Prof. Changliu Liu at CMU. During my M.S., I worked with Prof. Zeynep Temel and Prof. Oliver Kroemer. My research focuses on multimodal tactile sensing, dexterous manipulation, and robot learning. I am particularly interested in enabling robots to infer the underlying physical state through interaction before making decisions.

I received my B.S. in School of Mechanical Engineering at Shanghai Jiao Tong University in 2024, where I was fortunate to work with Prof. Genliang Chen on pneumatic grippers. This experience sparked my interest in manipulation and taught me that mechanical design is not merely a hardware component, but an integral part of how robots interact with and understand the physical world.

news

Sep 14, 2026 Will serve as Session Chair and Co-Chair for two tactile sensing sessions at IROS 2026!
Sep 04, 2026 Our paper on tactile representation learning was accepted to CORL 2026 !
Jun 17, 2026 Our paper on multi-modal robotic fingertip was accepted to IROS 2026 !
May 19, 2025 Presented the poster at the ICRA 2025 workshop “Handy Moves: Dexterity in Multi-Fingered Hands” !

selected publications

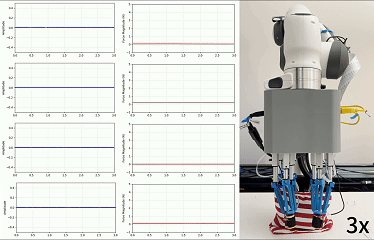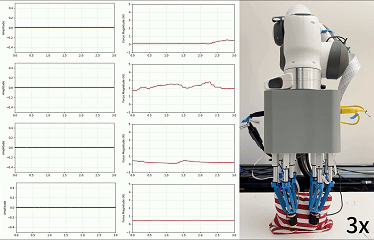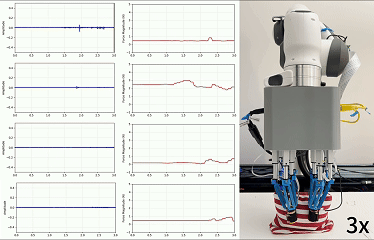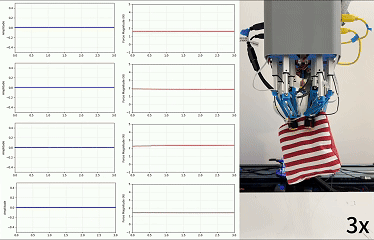
  1. sandbag.gif
    A multi-modal tactile fingertip design for robotic hands to enhance dexterous manipulation
    Zhuowei Xu, Zilin Si, Kevin Zhang, and 2 more authors
    IROS, 2026
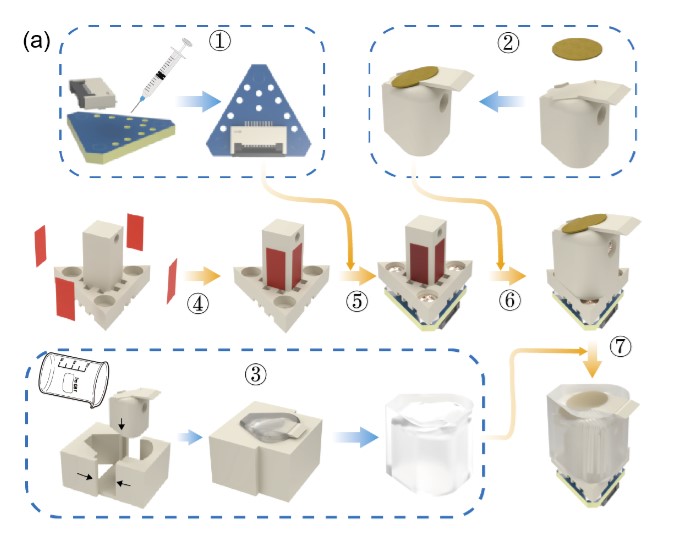
  2. fingertipmanufac.jpg
    A Low-Cost Tactile Fingertip Design for Dexterous Robotic Hands
    Zhuowei Xu, Zilin Si, Kevin Lee Zhang, and 4 more authors
    In ICRA 2025 Workshop ”Handy Moves: Dexterity in Multi-Fingered Hands” Paper Submission, 2025
  3. catchit.gif
    Lightweight and Powerful Vacuum-Driven Gripper With Bioinspired Elastic Spine
    Yongzhou Long, Zhuang Zhang, Zhuowei Xu, and 4 more authors
    IEEE Robotics and Automation Letters, 2023
selected projects

  1. Developed and evaluated tactile-augmented imitation learning policies for fragile and contact-rich manipulation. Across tofu pinching, chip pinching, and box opening, the results show that force feedback is most valuable when visual observations cannot precisely resolve contact state, improving chip pinching success from 1/10 to 6/10.
  2. Designed a kinematic-twin teleoperation system for whole-body control of a dexterous hand–arm robot. Direct joint mapping enables intuitive operation, while a real-time MuJoCo digital twin supports visualization and validation of teleoperation commands.
  3. Designed a tactile event extraction framework for object-centric manipulation, where long-horizon exploration is compressed into informative tactile tokens through a Top-K selector. The extracted object context enables policies to reason about localized physical properties and adapt manipulation actions accordingly.
  4. This project used an existing magnetic whiteboard-cleaning robot as a testbed for model-based motion control on vertical surfaces. I implemented and evaluated TVLQR and MPC trajectory tracking algorithms against a PID baseline, with MPC providing the most stable and robust erasing performance in hardware experiments.
  5. Worked on a galvo mirror–robot co-working platform that combines fast planar galvo scanning with 6-DoF robotic motion to extend the effective workspace into 3D. Developed a kinematic calibration and error-compensation model to estimate system parameters from planar images and improve spatial positioning accuracy.